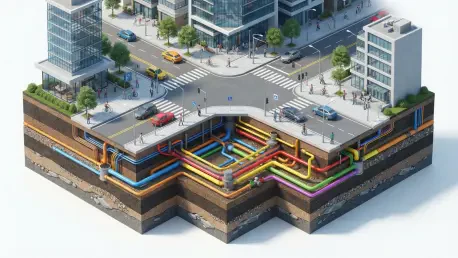
Experimental validation using OpenStreetMap datasets confirms that the BIM-GO model achieves a positioning accuracy of 95.6 percent in diverse geographic locations. The dense, invisible network of essential services—ranging from high-pressure gas lines to fiber-optic telecommunications—forms the lifeblood of modern urban centers, yet its management remains a profound engineering challenge. As cities continue to expand both vertically and horizontally, the subterranean labyrinth becomes increasingly congested, making accurate detection a necessity rather than a luxury. Hidden beneath thick layers of asphalt, reinforced concrete, and shifting soil, these utility systems are frequently disturbed by new construction projects due to inadequate mapping records. The introduction of the BIM-GO model marks a significant technological leap, moving beyond traditional visualization toward a mathematical framework where digital twins actively guide physical detection tools. By synthesizing Building Information Modeling with sophisticated graph optimization, this system offers a robust solution for navigating the complex environments that lie beneath our feet, ensuring that the critical infrastructure supporting modern life remains both accessible and safe during the rapid urban development witnessed in 2026.
Technical Limitations: The Hurdle of Conventional Subsurface Mapping
Conventional methods for locating pipelines, such as ground-penetrating radar and electromagnetic induction, face significant hurdles when deployed in complex urban soil environments. These technologies are often highly sensitive to environmental factors like varying moisture levels, the depth of burial, and electromagnetic interference from nearby metal objects or electrical lines. When a pipeline transitions between different materials, such as from metal to plastic, traditional sensors frequently lose the signal, resulting in incomplete or inaccurate data that can mislead engineers during critical excavation phases. The physics of these sensors often limits their effectiveness in highly conductive soils or areas with dense metallic clutter, which are common in older metropolitan districts. Consequently, relying solely on these older methods increases the risk of utility strikes, which can lead to catastrophic failures, environmental hazards, and immense financial liabilities for municipalities and private contractors alike.
Beyond the immediate environmental interference, older detection methods typically provide only a static snapshot of a location rather than a continuous, real-time trajectory. This lack of dynamic data often leads to errors during excavation, posing risks to public safety and infrastructure integrity. While inertial navigation was previously explored to solve these issues, earlier attempts often failed to deeply integrate sensor data with structural models, leaving a gap between raw measurements and physical reality. The absence of a unified mathematical framework meant that sensors could easily drift over long distances, losing their orientation within the dark, enclosed spaces of a pipeline. Without a reliable way to reconcile sensor readings with the known layout of the city, detection tools were essentially working in a vacuum. This technological isolation made it difficult to maintain high-level accuracy across extensive utility networks, forcing engineers to rely on manual verification and slow, piecemeal mapping strategies that could not keep pace with the needs of 2026.
Integrating Sensor Fusion: The Foundation of Pre-integration
The BIM-GO framework functions by merging data from high-precision Inertial Measurement Units, which track orientation and motion through three-axis accelerometers and gyroscopes, with odometer readings that record physical distance traveled. To prevent the system from becoming overwhelmed by the massive influx of real-time data, the model utilizes a technique known as IMU pre-integration. This method compresses high-frequency sensor information into manageable constraints between discrete navigation states, allowing for faster processing without sacrificing the detail necessary for accurate mapping. By treating these high-speed readings as singular relative constraints, the system reduces the computational load on the central processor, which is essential for maintaining a smooth operational flow during field inspections. This approach ensures that even as the sensor moves rapidly through a pipe, the mathematical representation of its path remains stable and responsive to small changes in orientation or velocity.
This integration is vital for overcoming the drift errors that naturally occur in inertial sensors over time, where small measurement biases accumulate into large positional discrepancies. By balancing the speed of data updates with the need for mathematical precision, the system maintains a stable understanding of the sensor’s movement relative to its starting point. This foundational data layer ensures that the mapping tool can track its position accurately even when moving through long, winding sections of the underground network where external signals like GPS are completely unavailable. The pre-integration strategy acts as a filter, smoothing out the noise inherent in raw sensor data while preserving the critical motion signatures that define the pipeline’s unique geometry. This allows the BIM-GO model to maintain a high degree of confidence in its estimated trajectory, providing a reliable stream of data that serves as the input for more complex optimization algorithms downstream in the processing pipeline.
Mathematical Precision: Graph Optimization and Spatial Constraints
At the heart of the BIM-GO model is a graph optimization algorithm that treats the entire detection path as a series of connected nodes and edges. Each node represents the specific position and orientation of the sensor at a given moment in time, while the edges represent the relative movement data collected by the sensors between those moments. By modeling the trajectory in this way, the system can use non-linear least squares optimization to smooth out errors and find the most mathematically probable path through the pipe. This method allows the system to look back at the entire history of the movement and adjust past positions based on new information, ensuring that the entire map is internally consistent. Instead of relying on a single, potentially flawed data point at the end of the run, the graph optimization process minimizes the total error across the entire path, resulting in a trajectory that is far more accurate than what could be achieved through simple dead reckoning.
The most innovative feature of the BIM-GO model is its use of existing Building Information Modeling data as a virtual landmark to anchor the sensor readings. In traditional navigation, if a sensor drifts, the error grows unchecked until the data becomes useless for engineering purposes. However, the BIM-GO model treats known pipeline nodes from the BIM database as soft constraints that pull the estimated trajectory back toward the documented physical layout of the pipe. This creates a feedback loop where the digital model of the city acts as a corrective force for the physical sensors. If the sensor starts to report a path that deviates from where the pipe is known to be located in the BIM environment, the optimization algorithm adjusts the trajectory to align with the model. This synergy prevents the accumulation of long-distance errors, making it possible to map extensive utility networks with unprecedented reliability. The combination of flexible sensor data and rigid architectural constraints allows the system to thrive in environments where traditional mapping would fail.
Smart City Management: Implementation and Actionable Strategies
To maintain accuracy over long distances or through complex networks, the model included a revisit detection mechanism that monitored the unique waveforms created by the pipe’s turns and joints. As the sensor passed through an area it had navigated before, the system recognized the pattern and performed a correlation analysis to match the current location with historical data. Once a match was confirmed, the system created a loop-closure constraint, which effectively pinned the two points together in the mathematical graph. This allowed the model to retroactively correct any errors that occurred between the two visits, significantly suppressing time-varying sensor bias. The researchers found that this mechanism ensured the map remained accurate even during lengthy inspections of intricate underground systems, where traditional drift would have otherwise rendered the data unusable. This feature provided an additional layer of verification that proved essential for mapping large-scale municipal infrastructure.
The successful implementation of the BIM-GO model demonstrated that moving toward a digital twin strategy for urban infrastructure is not only feasible but necessary for the safety and efficiency of 2026 city management. To capitalize on these findings, municipalities should prioritize the digitization of legacy utility records into high-fidelity BIM environments, as these models serve as the essential anchors for modern positioning technology. Engineering firms were advised to adopt sensor fusion platforms that support graph optimization to replace aging, snapshot-based detection tools. Future development efforts focused on refining these algorithms to handle extreme environments, such as pipes with irregular diameters or those submerged in high-interference materials. By integrating digital modeling with real-time physical sensing, cities improved their ability to plan repairs, reduced the frequency of accidental utility strikes, and ensured that the vital subterranean lifelines of the population remained precisely documented and protected for years to come.